Bringing dynamic route intelligence to UGVs at the edge
Discover how Carmenta Terrain Router integrates with ROS 2 Nav2 to enable real-time UGV route replanning, terrain-aware navigation, and improved survivability.
Read more
Determining safe landing zones is an essential part of many types of UAS missions. Two examples of such UAS missions is delivering supplies to military ops and doing emergency medical delivery.
In many cases it is also important to identify safe landing zones along the route in case of an emergency during a flight.

Candidates for safe landing zones can be calculated during the flight planning in the mission preparation. During the flight, sensors and AI signal processing onboard the UAS can be used to evaluate these candidates as well as finding additional safe landing sites.
Certain conditions must be met to classify an area as a good candidate as a safe landing site:
When it comes to preparing the flight for the mission, Carmenta Engine can help the operator to analyze the terrain and identify safe landing zones, so that the drone can start its mission with good candidate areas where it can land safely.
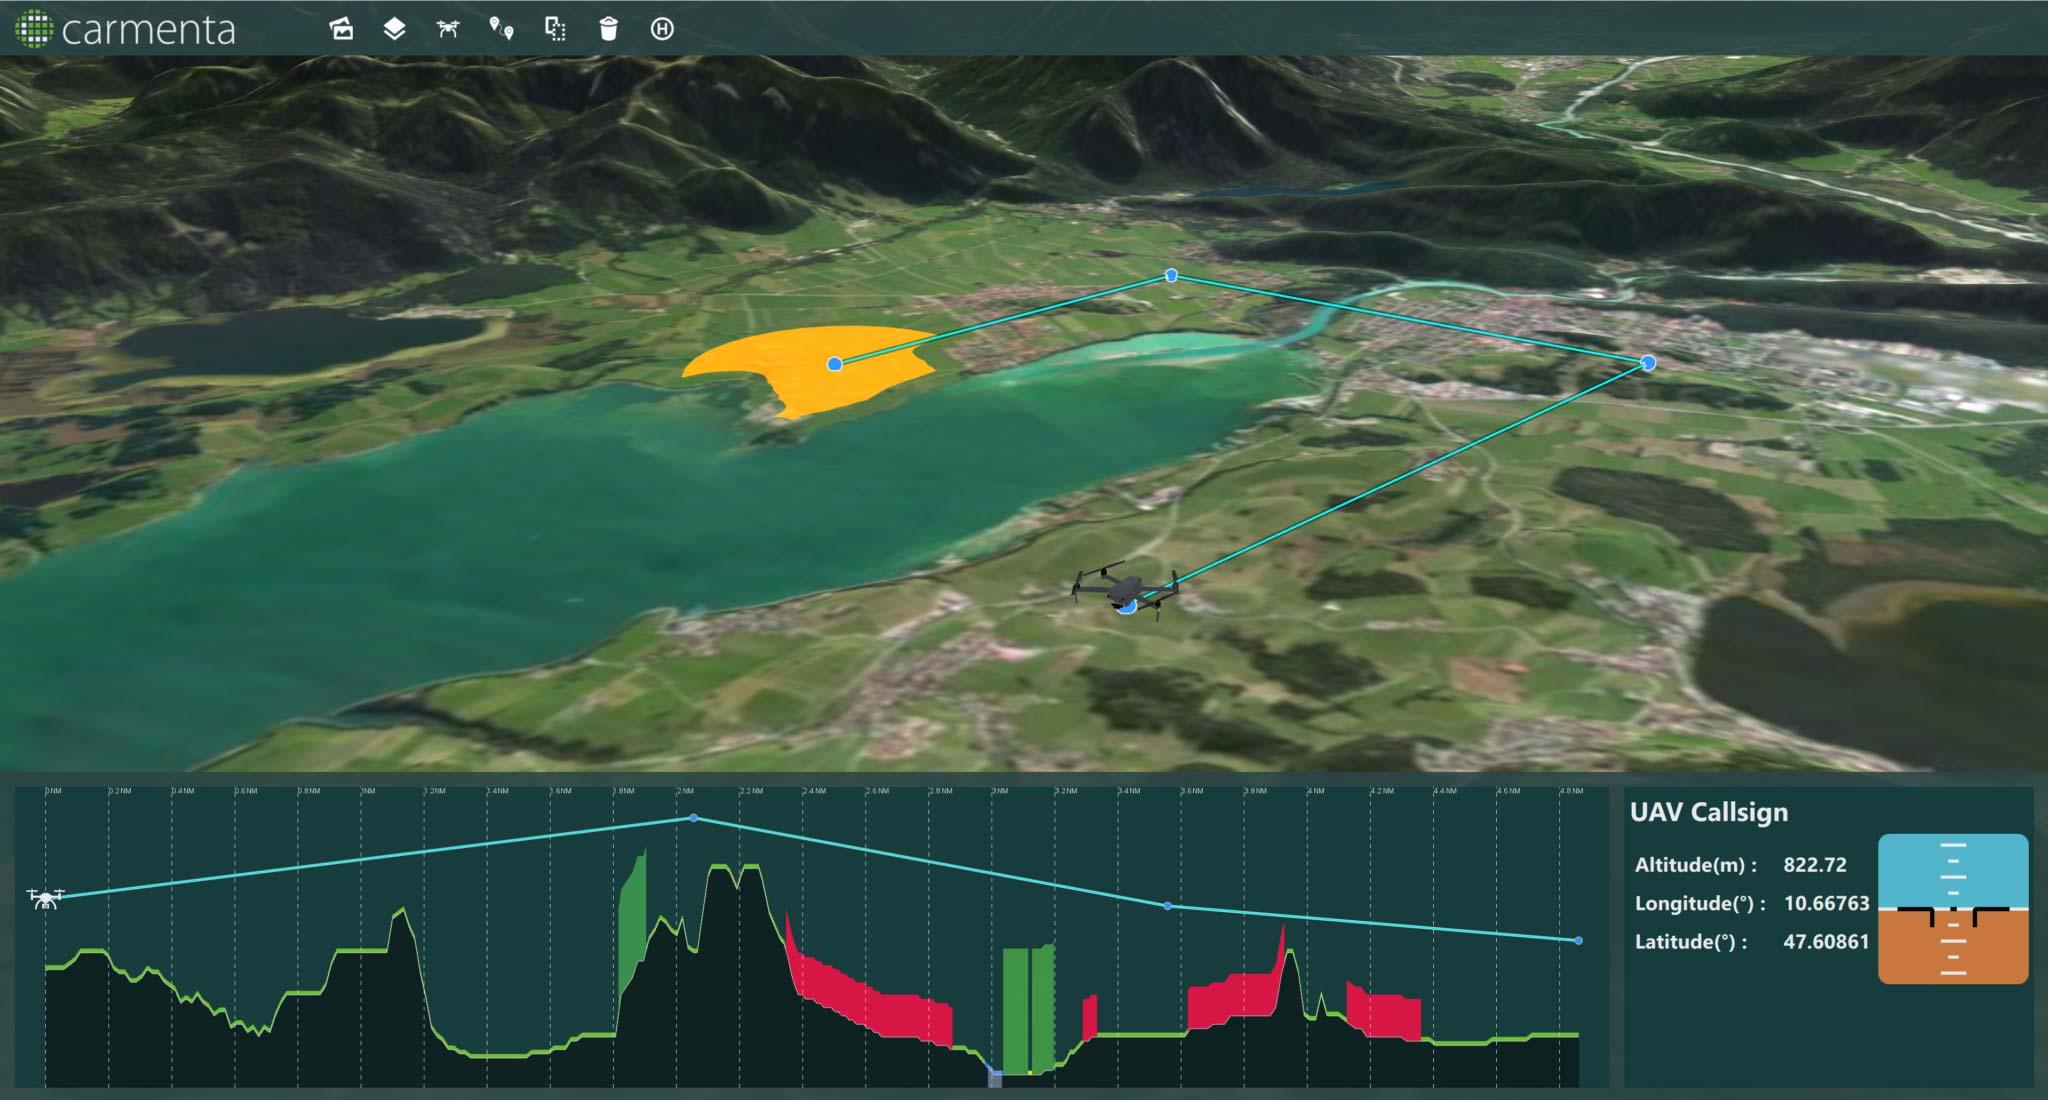
Carmenta Engine can help you to in real time calculate the best UAS route for a mission taking a number of parameters, including terrain, into account. The picture below shows an example of a generated route between several waypoints that avoids a non-fly zone.
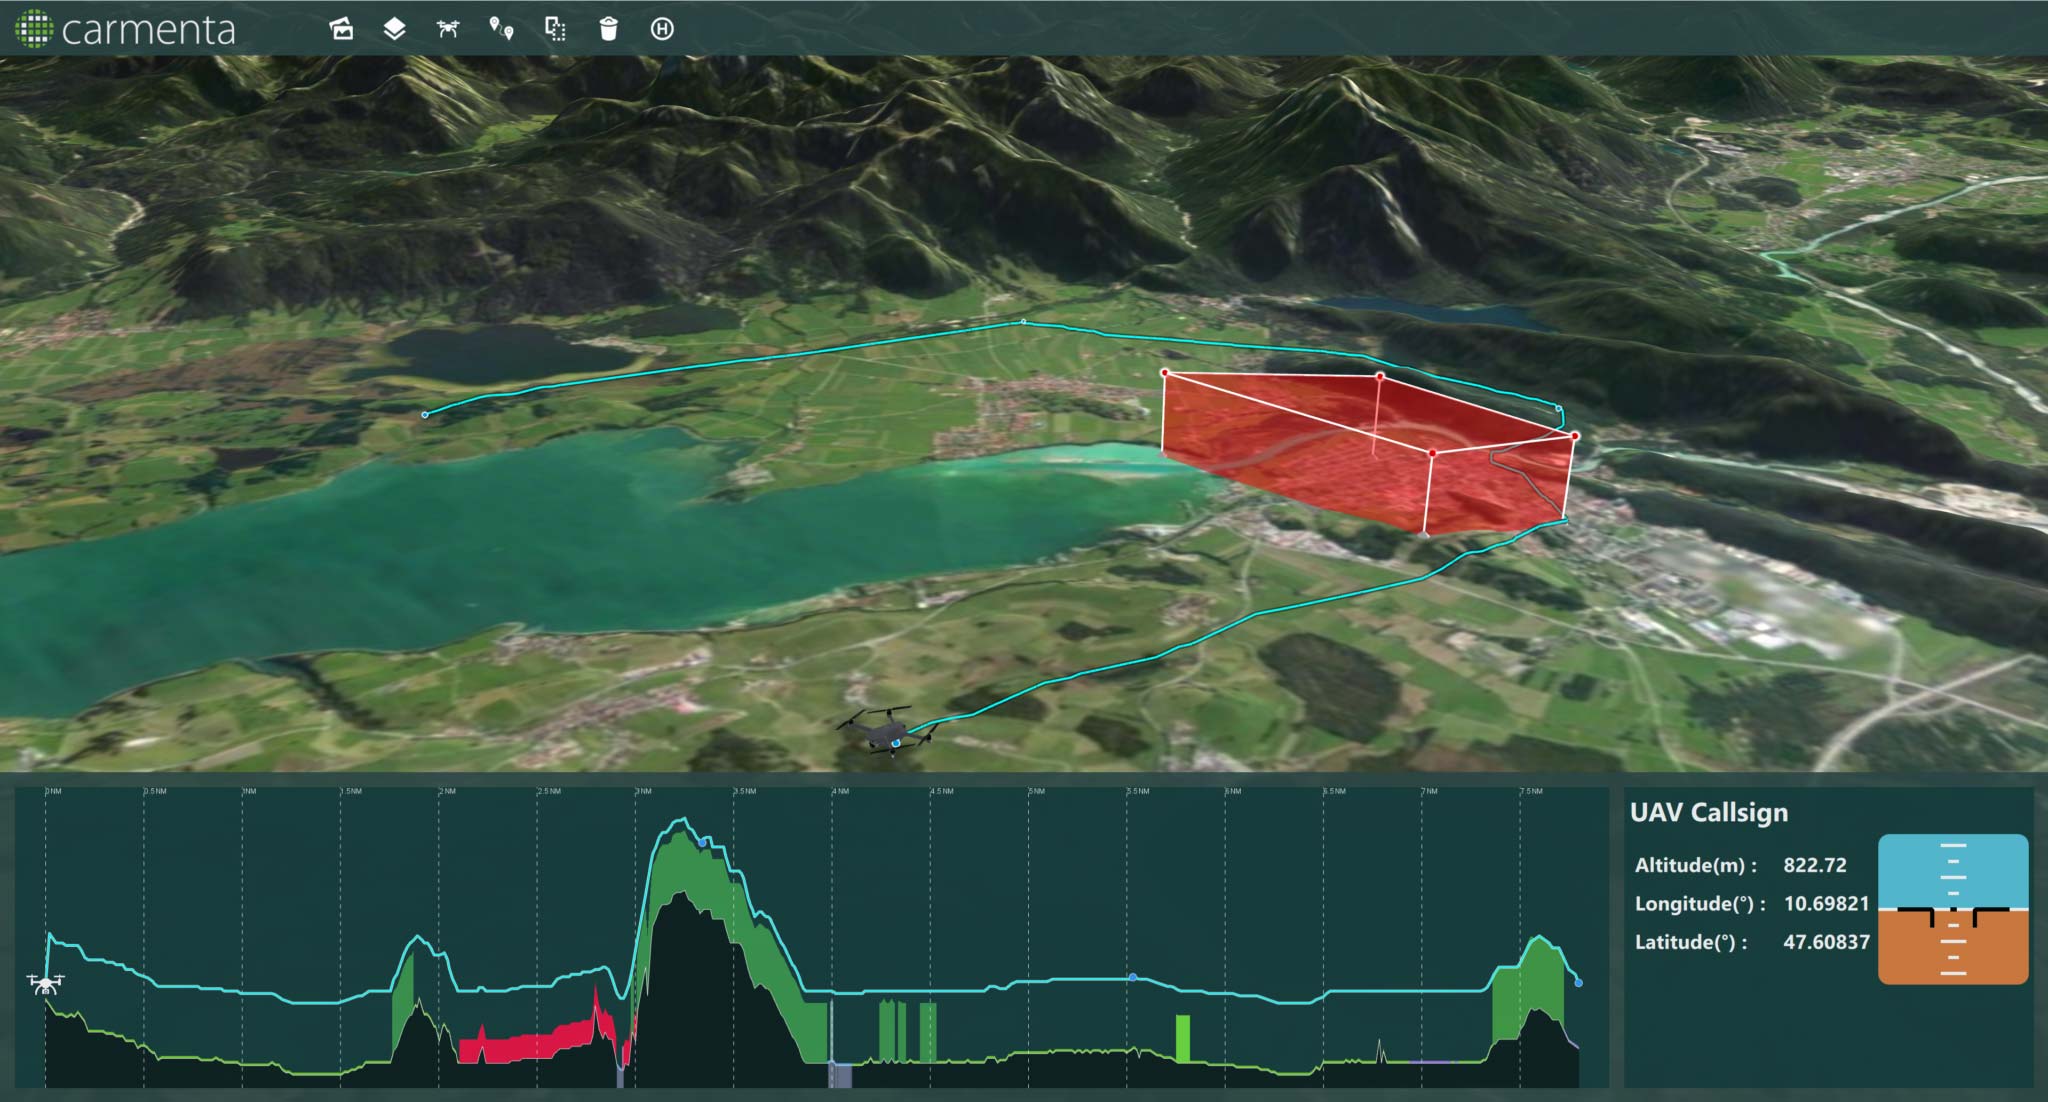
Route that follows the terrain and avoids a non-fly zone.
As soon as a route has been generated the terrain is further analyzed by Carmenta Engine and areas that are candidates for use as emergency landing zones during the flight are calculated and displayed along the route as shown in the picture below.
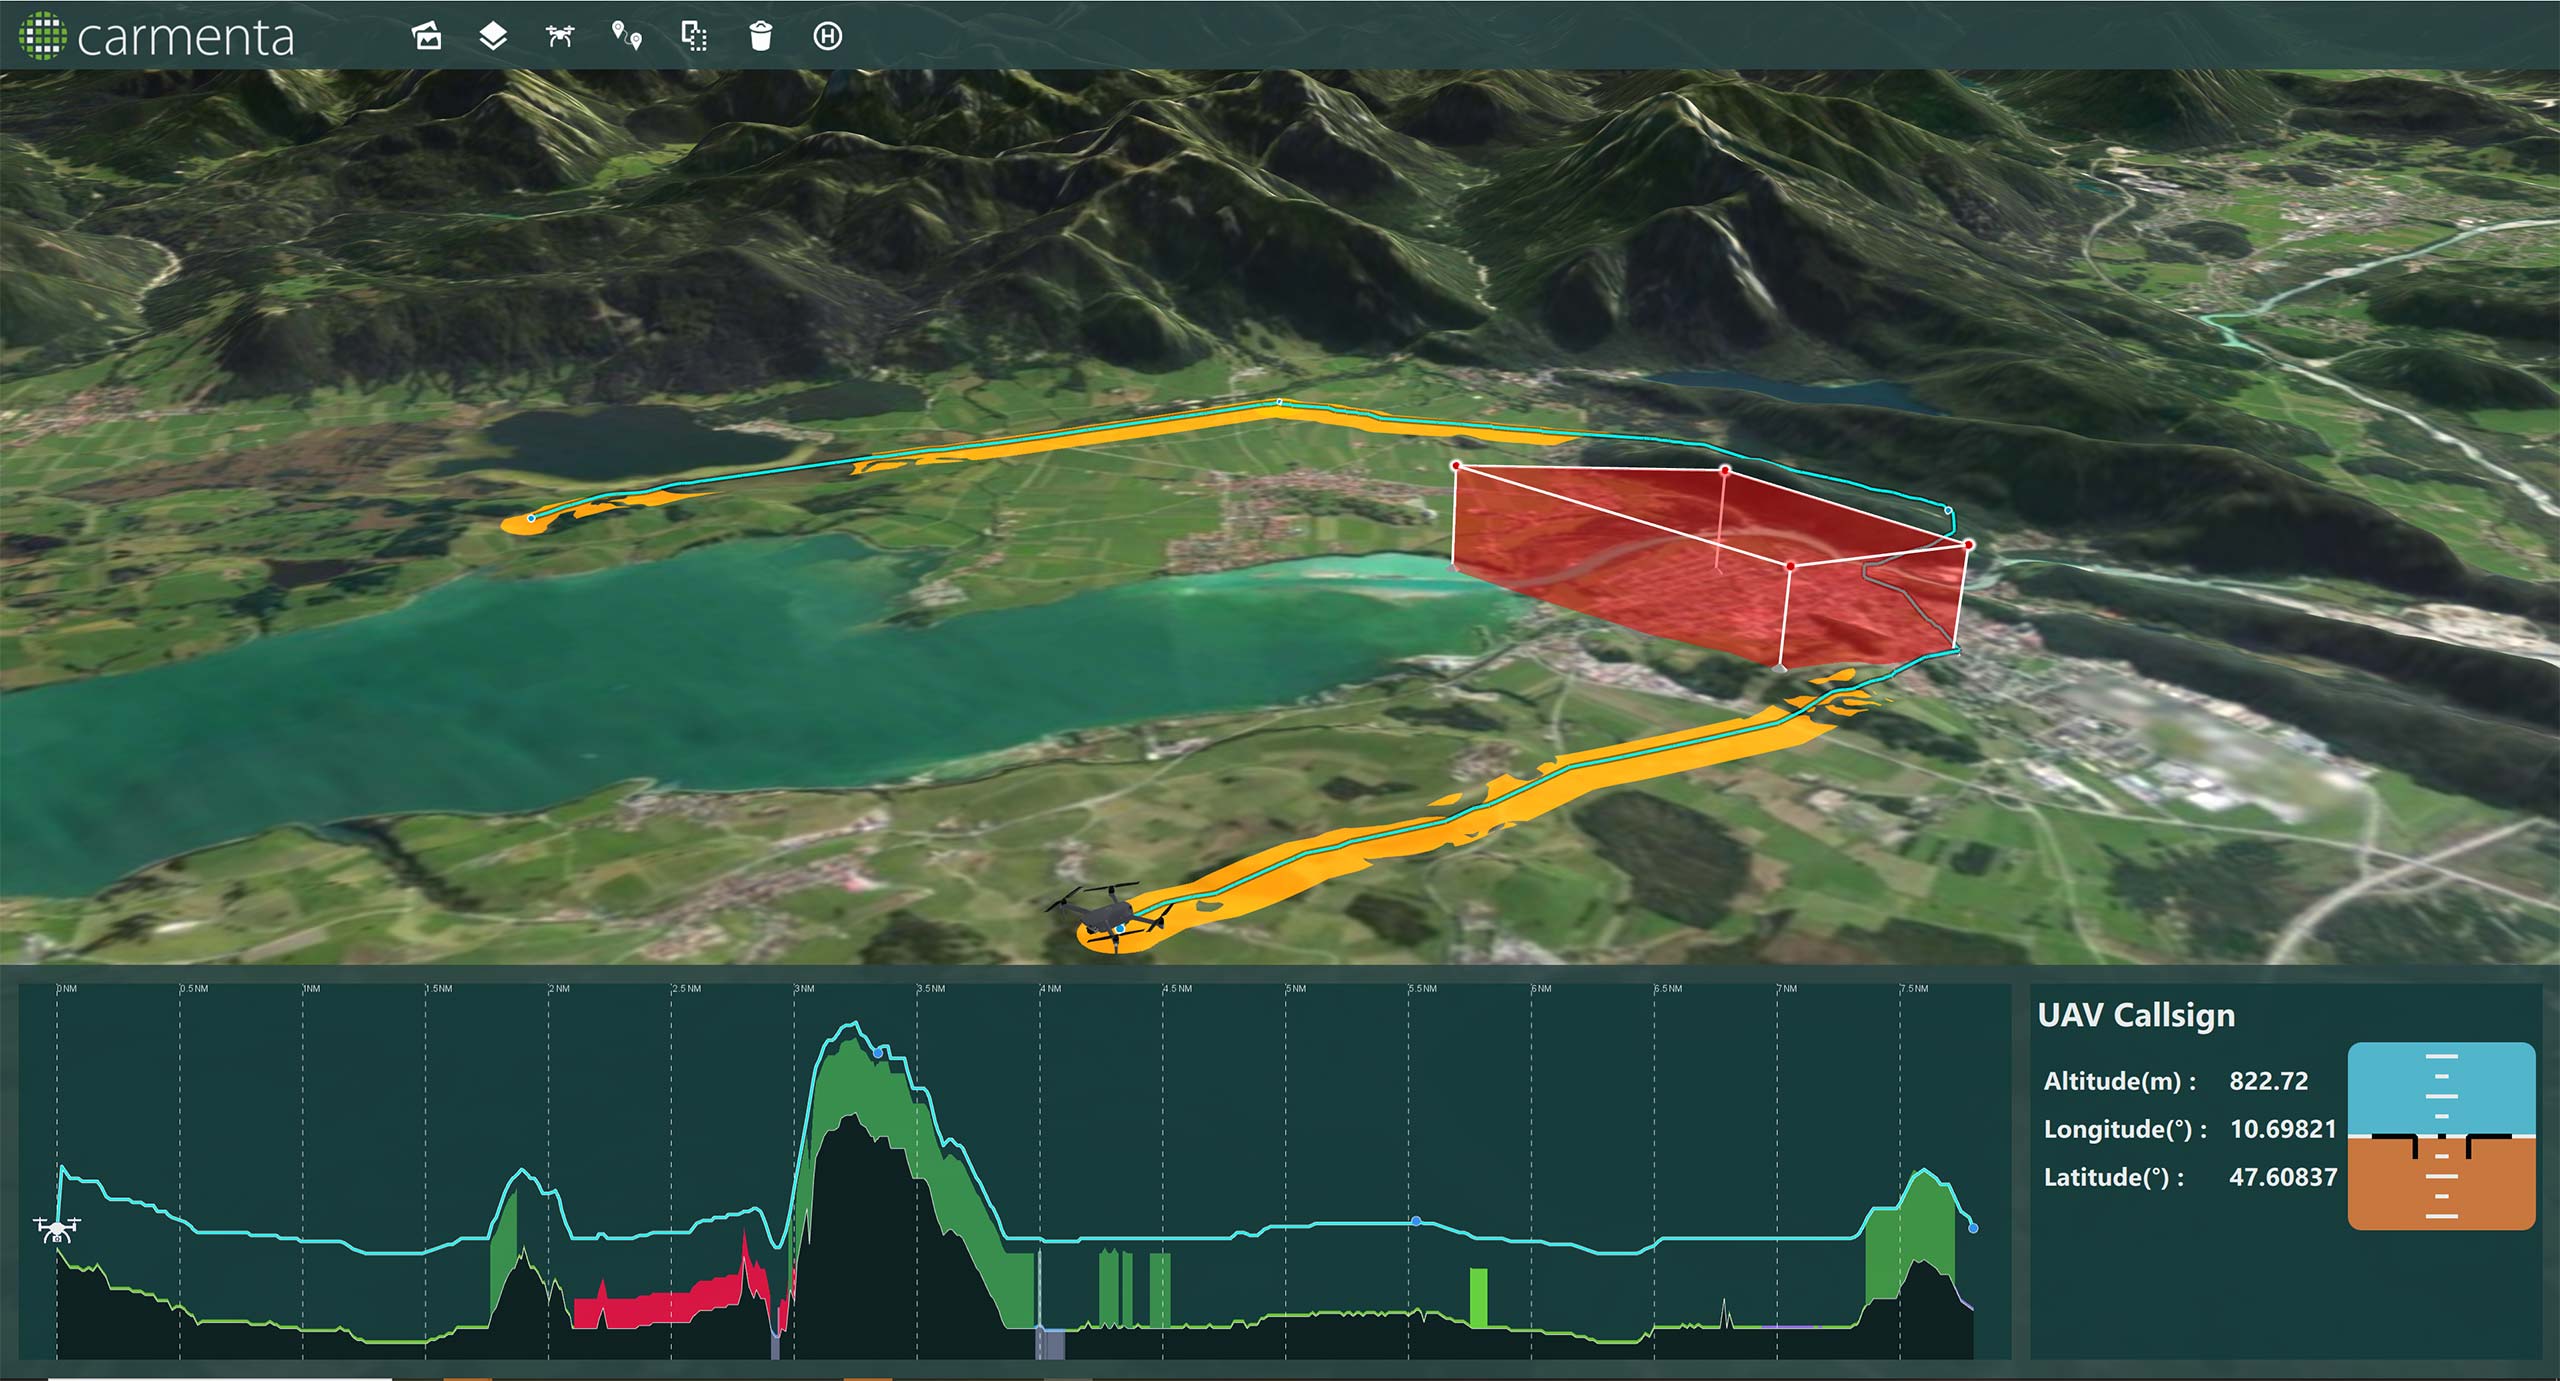
Safe emergency landing zones displayed along the route.
Another example show how Carmenta Engine can find a safe landing zone for the destination of a mission (e.g., medical supply delivery). When the route is being created, we calculate the proposed landing zone using a buffer around the last waypoint.
Safe landing zones displayed around destination.
Ground clearance: A landing zone requires some minimum distance to obstacles. Areas with sufficient ground clearance can be calculated with the buffer zone operator applied to a terrain type raster using a negative buffer to get polygons that are sufficient distance from unsafe terrain.
Slope constraint: Slopes greater than certain degrees are not suitable. Places with sufficiently large surroundings with sufficiently flat ground can be computed using a buffer zone operator in combination with isoline and slope operators.
Discover how Carmenta Terrain Router integrates with ROS 2 Nav2 to enable real-time UGV route replanning, terrain-aware navigation, and improved survivability.
Read more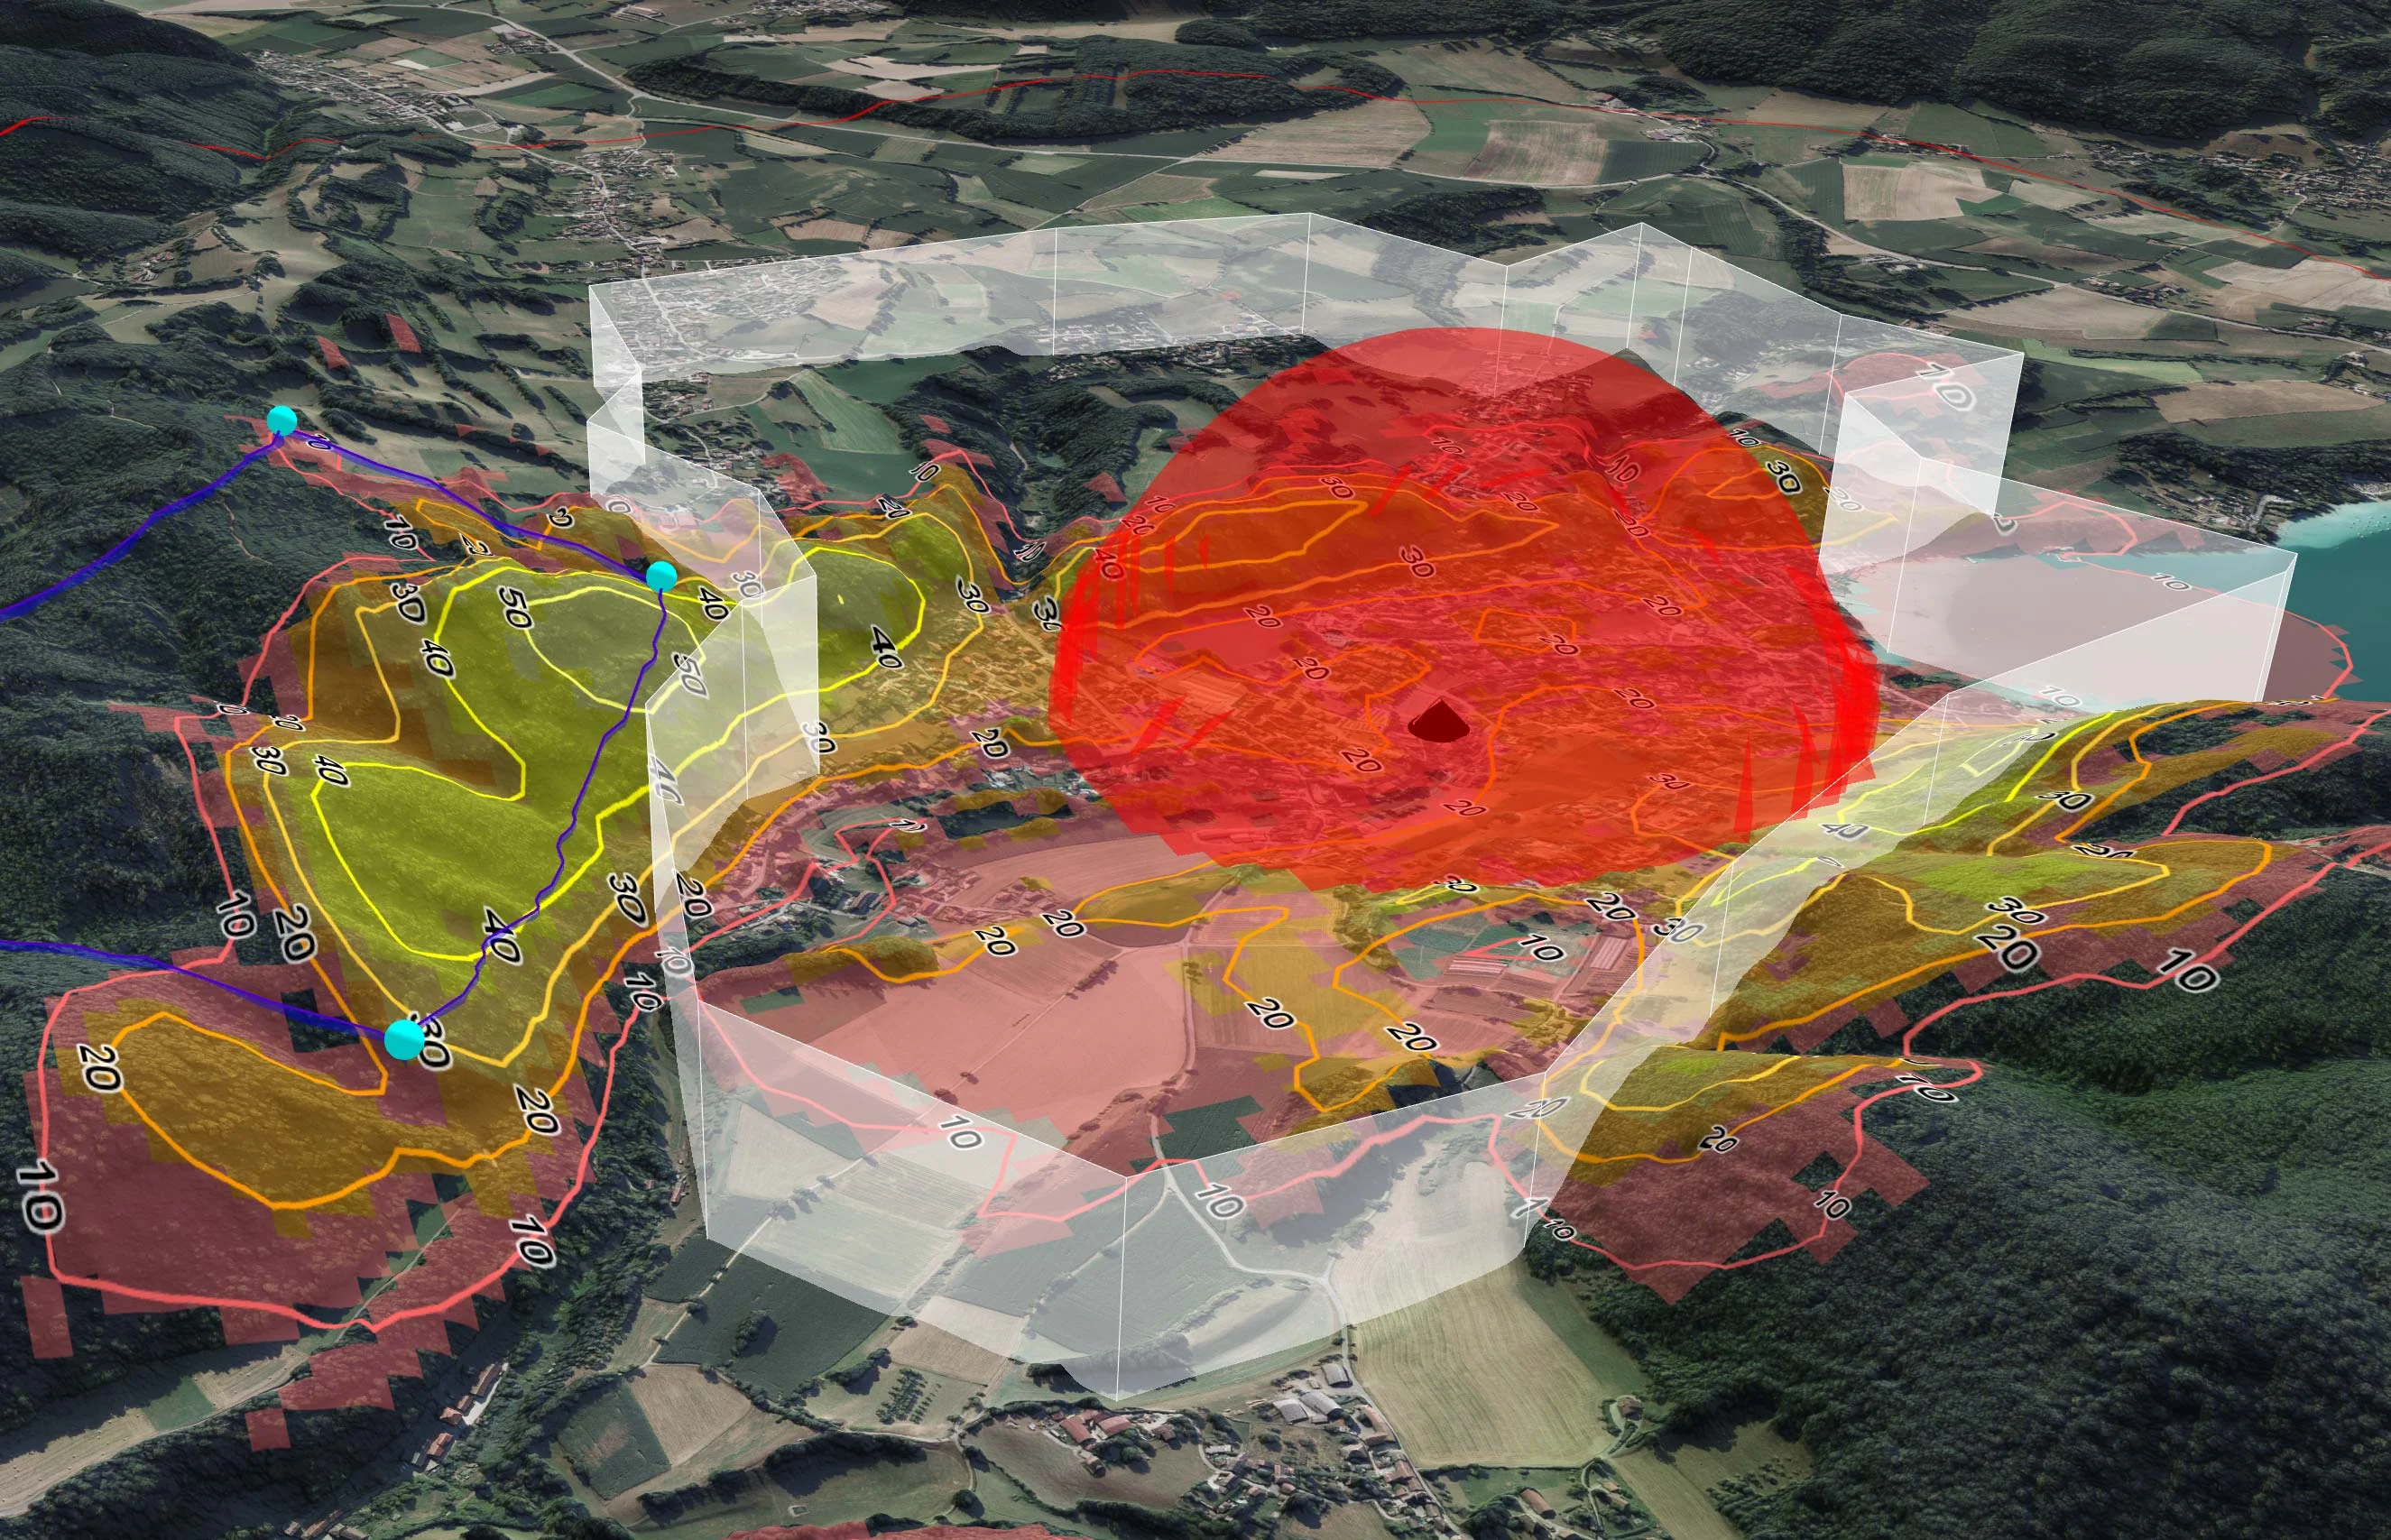
TRL Accel are currently developing a lightweight, modular UAS demonstrator that requires a high-performance C2 software solution. To solve several technical challenges and keep ambitious timelines on track, they turned to Carmenta UAS Mission Kit.
Read more
Celab Communications uses both Carmenta Engine and Carmenta Server to power solutions that enhance personal security for business personnel and first responders in the field.
Read more