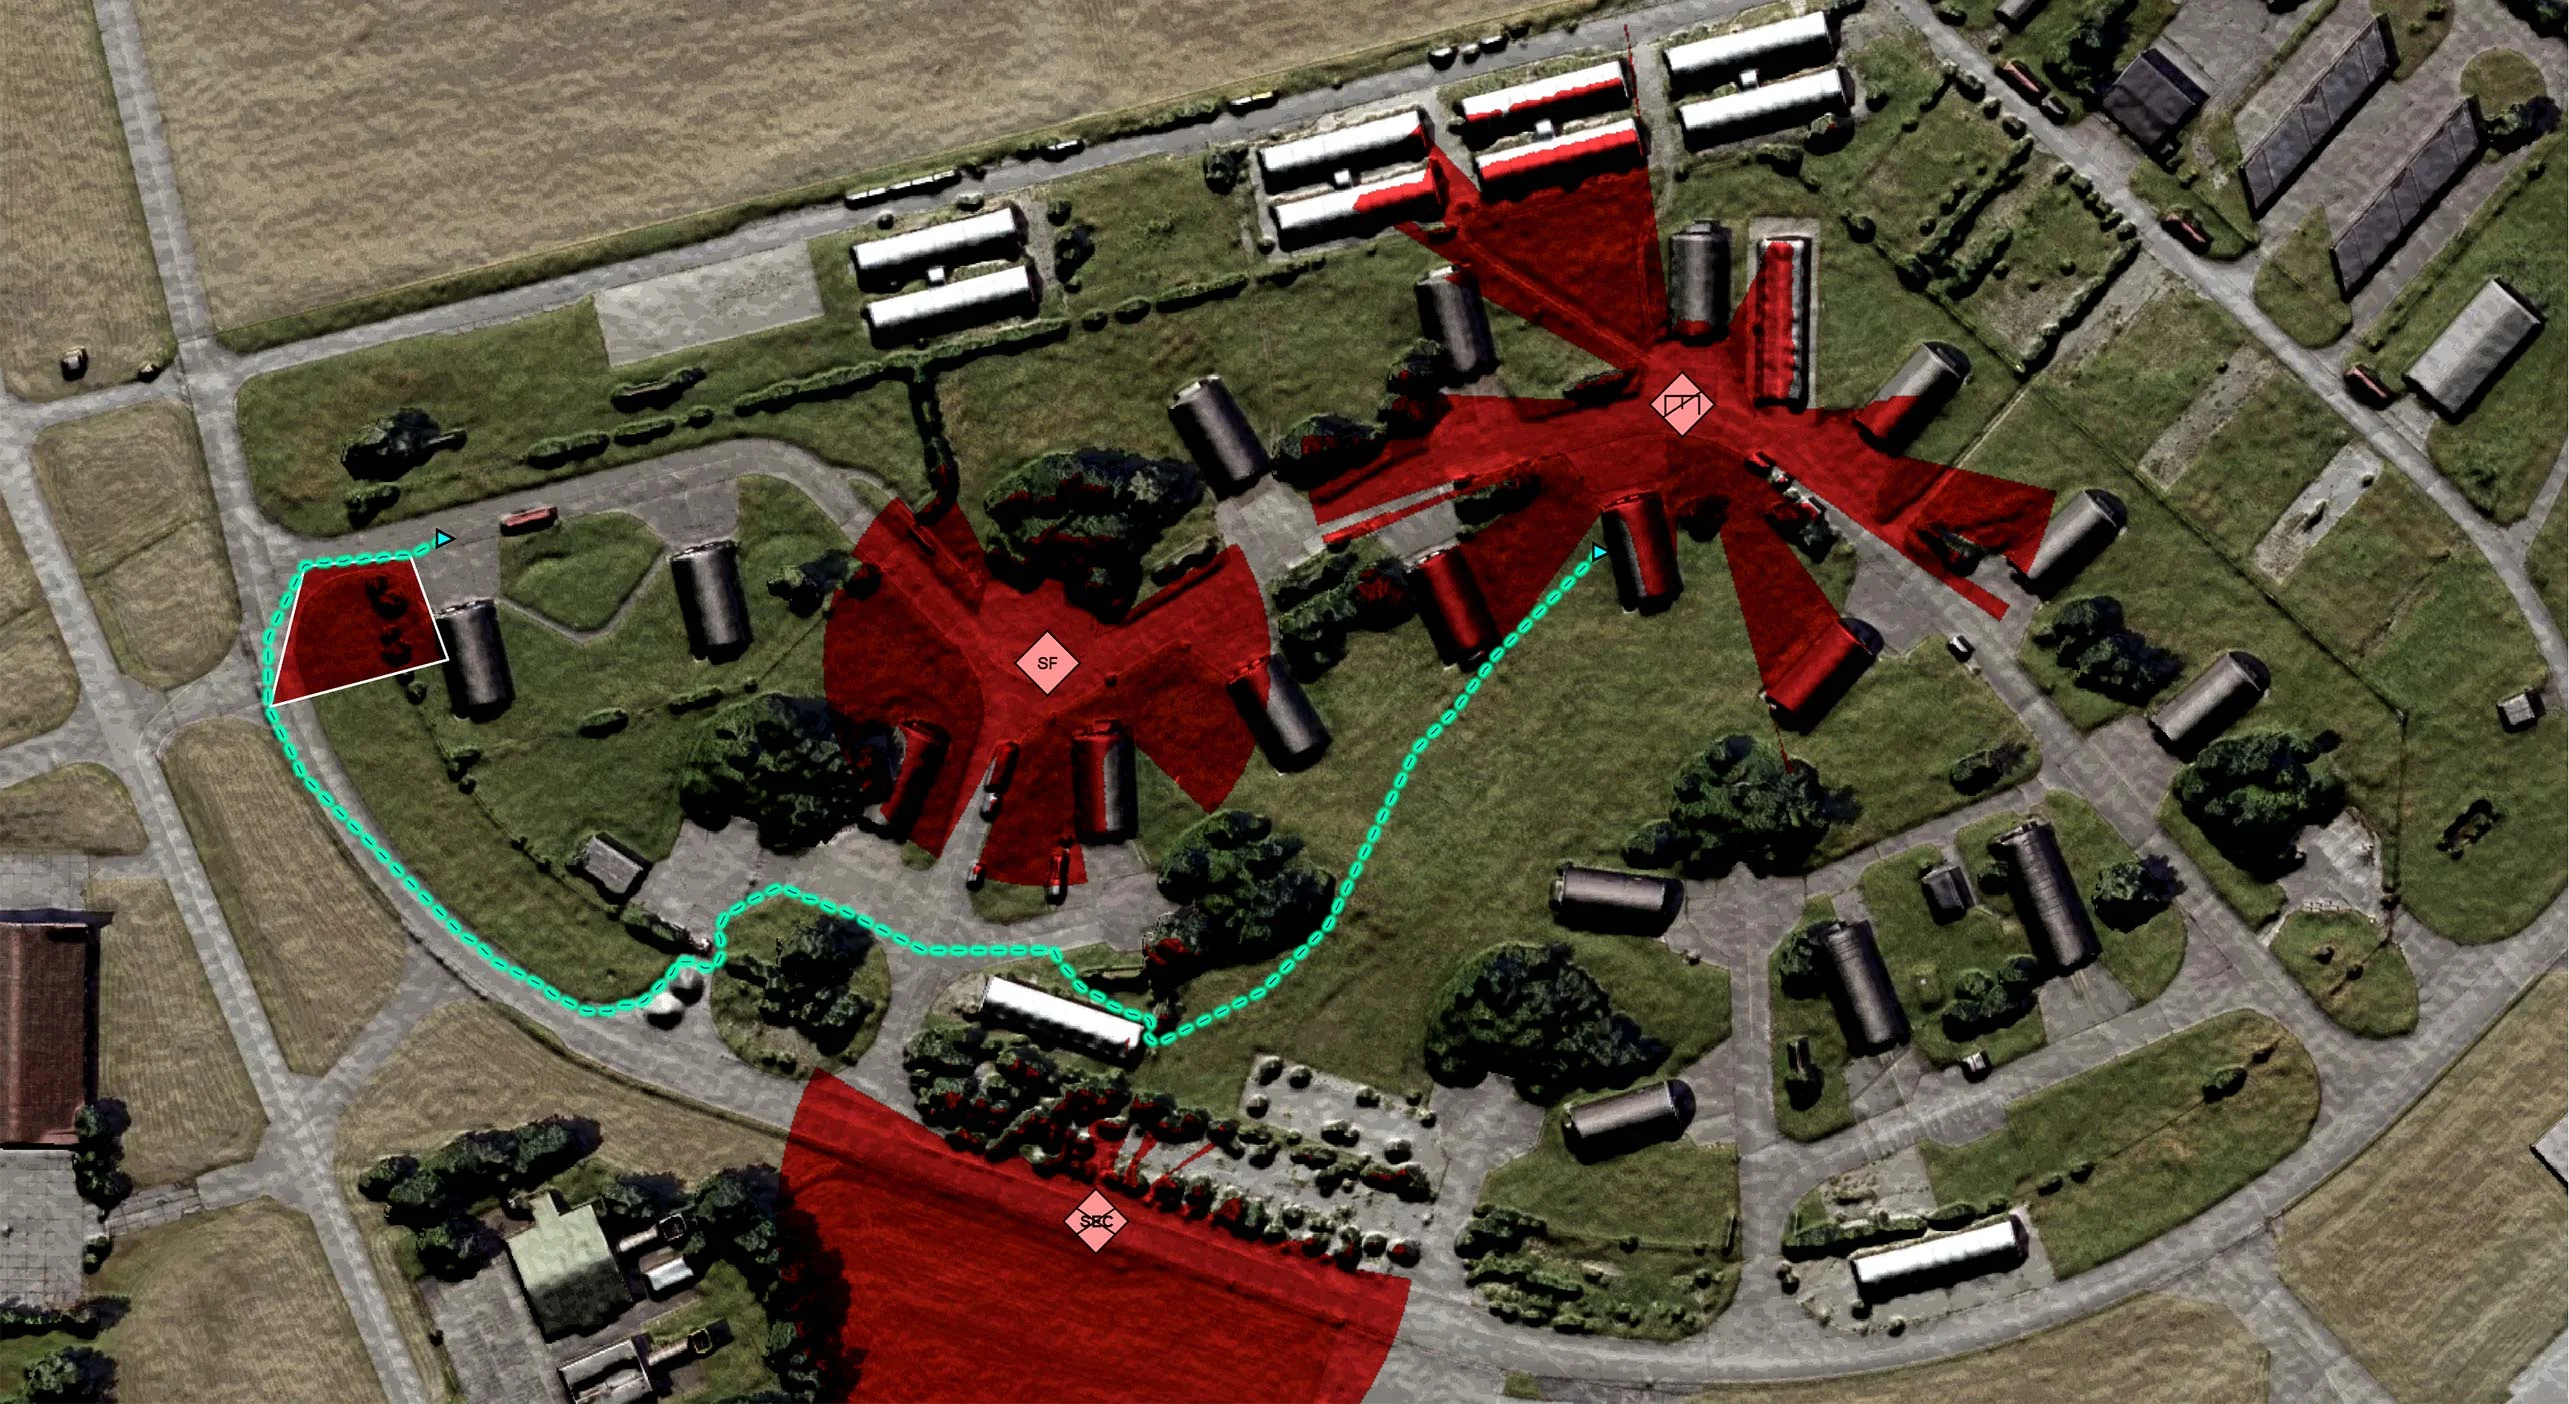
Bringing dynamic route intelligence to UGVs at the edge
Discover how Carmenta Terrain Router integrates with ROS 2 Nav2 to enable real-time UGV route replanning, terrain-aware navigation, and improved survivability.
Read more
Watch our webinar about shoot-and-scoot tactics using the traveling salesman problem.
When presented at GVSETS 2025 in August, our technical paper “Optimizing Firing Position Usage for Survivability and Effectiveness in Artillery Shoot-and-Scoot Tactics” was honoured with the Best Paper Award in the Autonomy, Artificial Intelligence & Robotics track.
If you missed the live talk, there is now a chance to watch the full recorded webinar.
The webinar is presented by Thomas Jonsson Damgaard, Developer at Carmenta and Co-author of the paper together with Dr. Mikael Rittri.
Webinar highlights:
Discover how Carmenta Terrain Router integrates with ROS 2 Nav2 to enable real-time UGV route replanning, terrain-aware navigation, and improved survivability.
Read more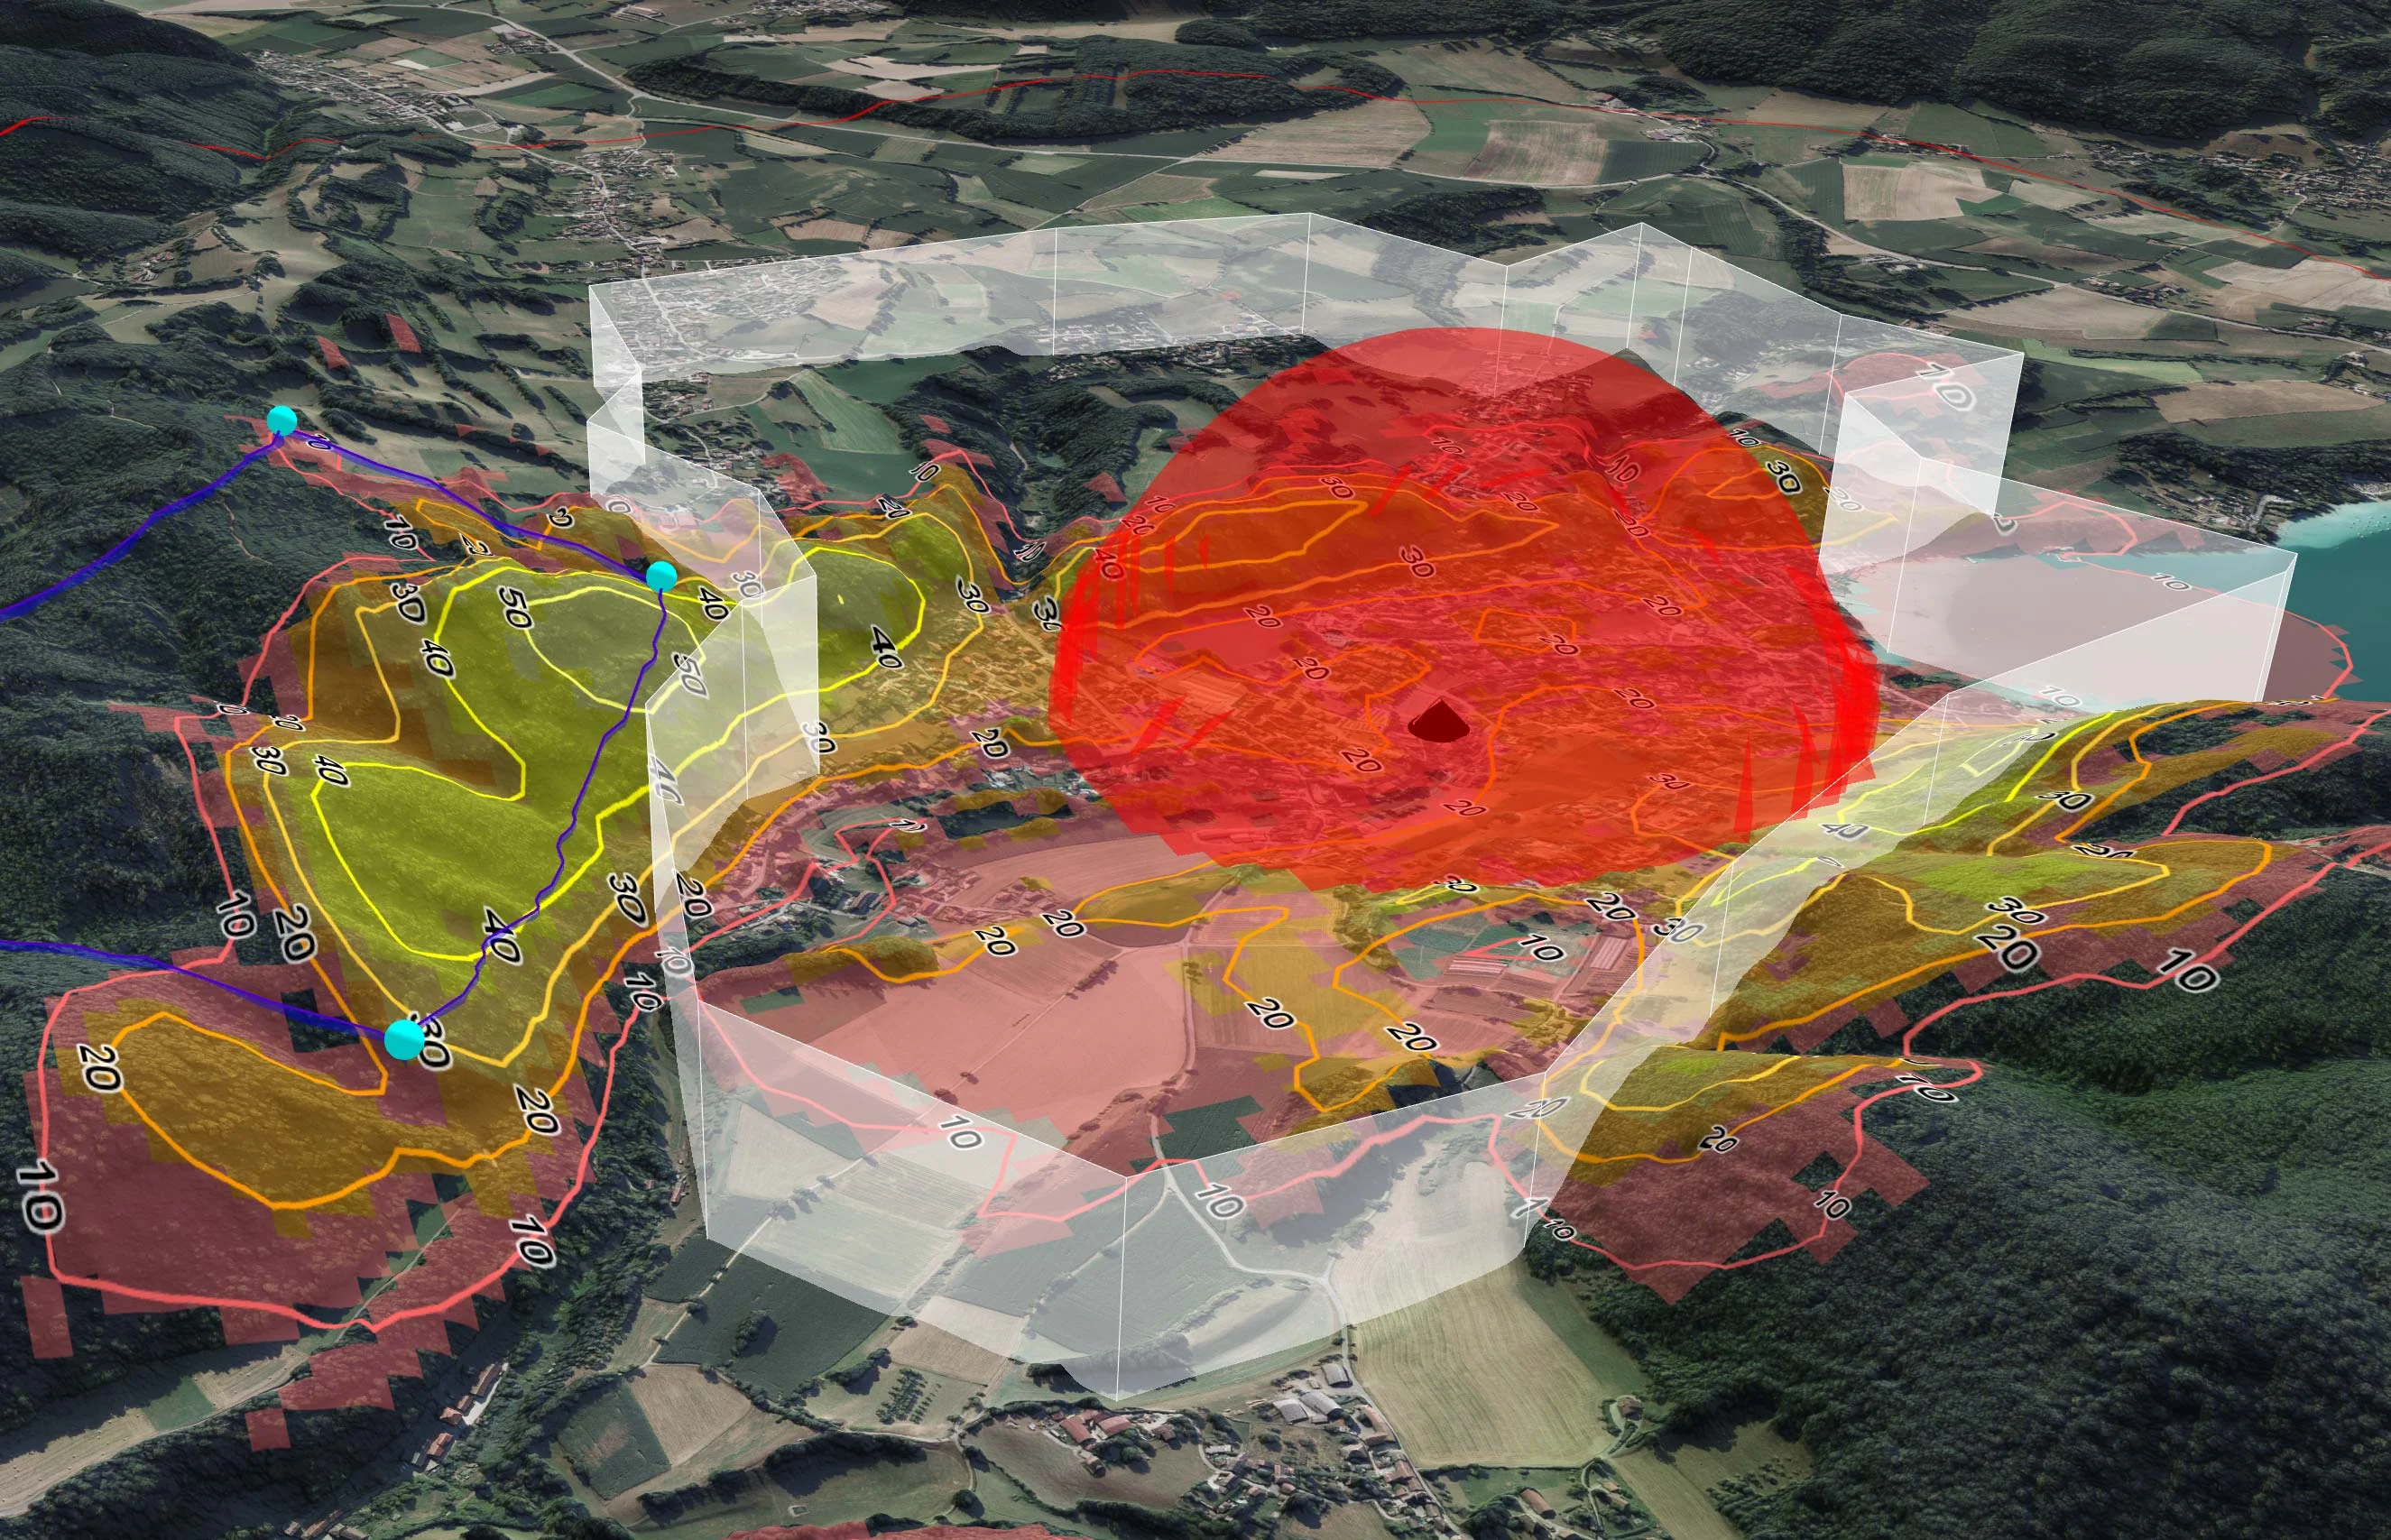
TRL Accel are currently developing a lightweight, modular UAS demonstrator that requires a high-performance C2 software solution. To solve several technical challenges and keep ambitious timelines on track, they turned to Carmenta UAS Mission Kit.
Read more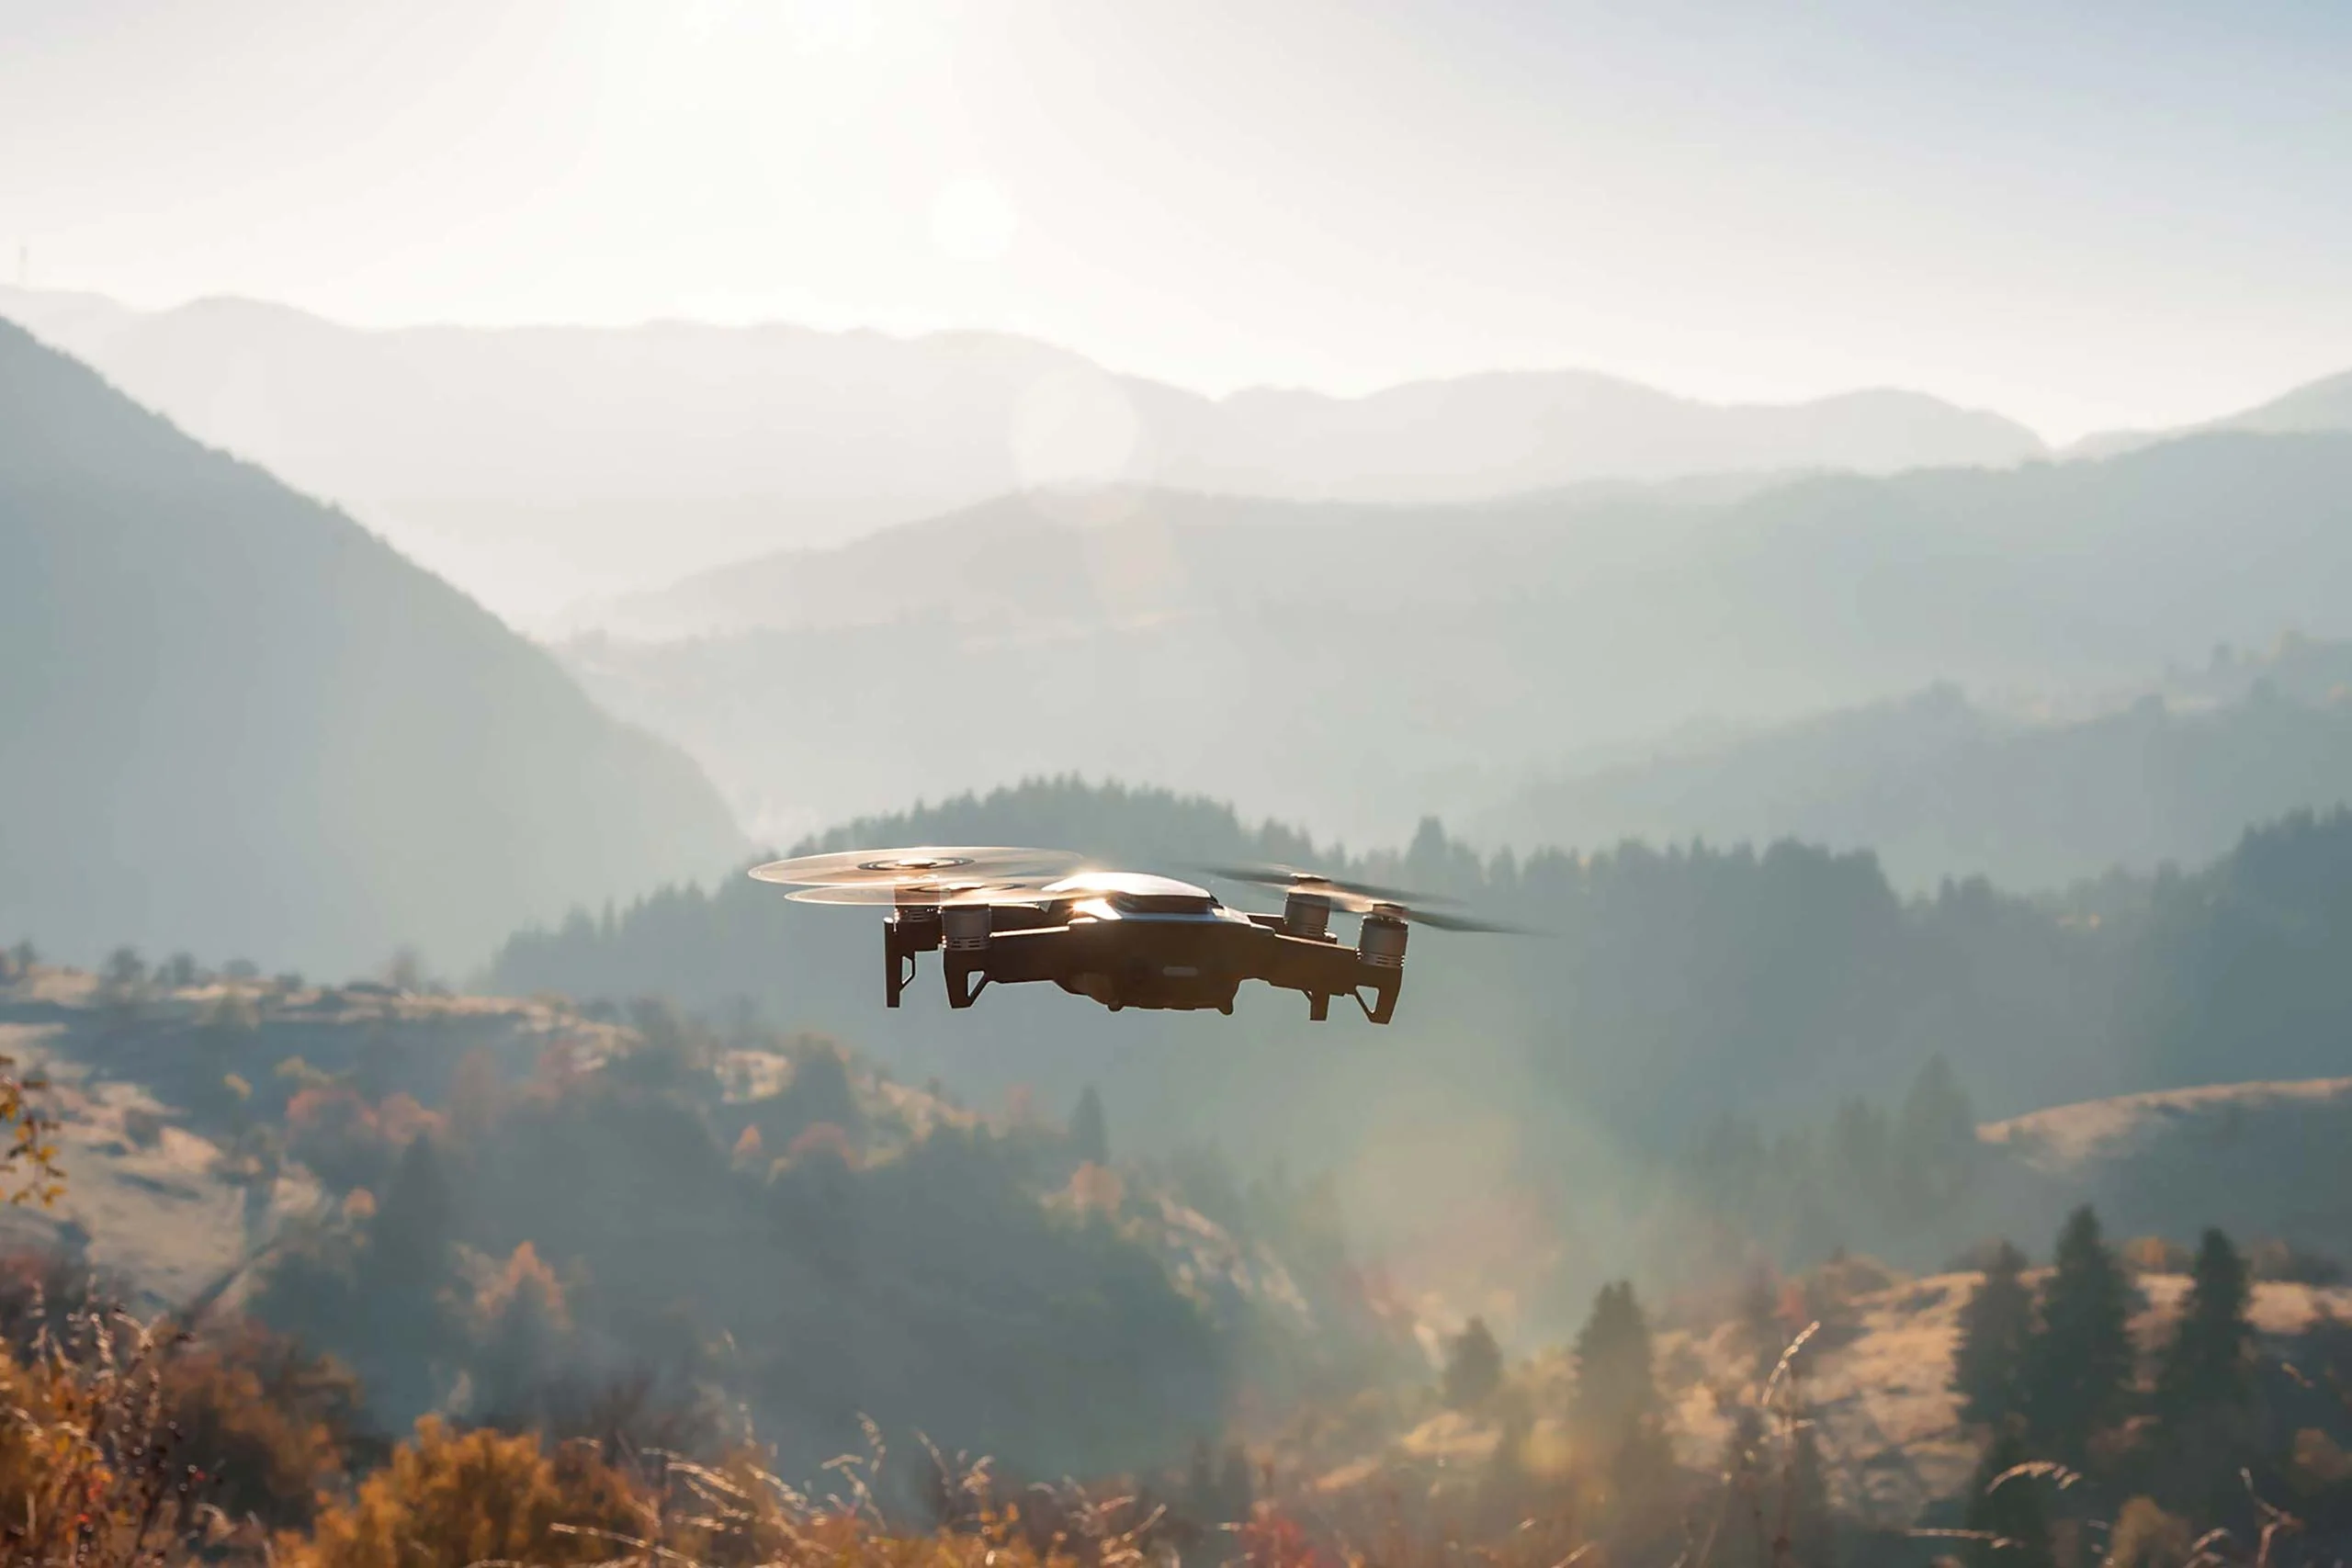
The evolving threat landscape in military operations underscores the importance of precise, adaptive, and intelligence-driven mission planning. Explore how geospatial analysis empowers UAVs to adapt to these challenges by enhancing situational awareness and supporting human and autonomous decision-making processes.
Read more